
Robohand Applications
Made in the USA
Builders and integrators use Robohand wherever a robot, gantry or pick-and-place unit has to handle a part: assembly stations, machine tending, packaging, inspection and palletizing. The part decides the gripper; the number of different parts the cell handles decides whether a tool changer or electric gripper earns its place.
Common applications
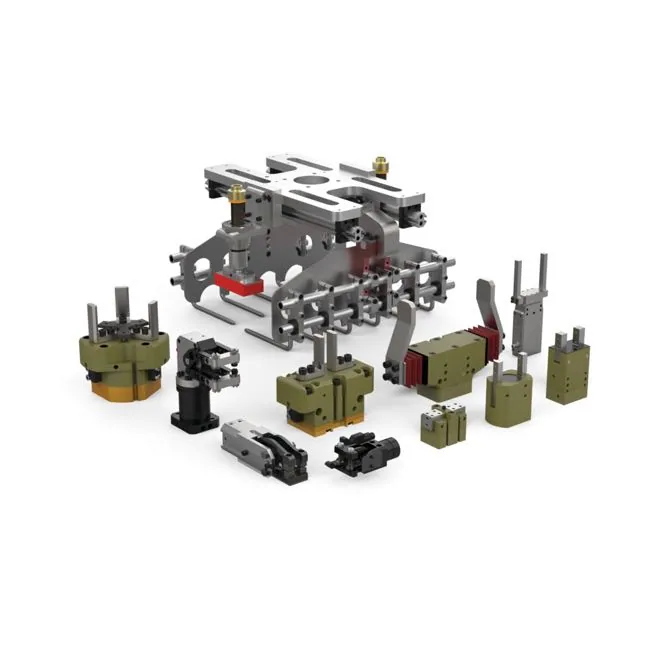
Pick and place at a station
Picking oriented parts from a feeder, indexer or conveyor and placing them into a nest or fixture.
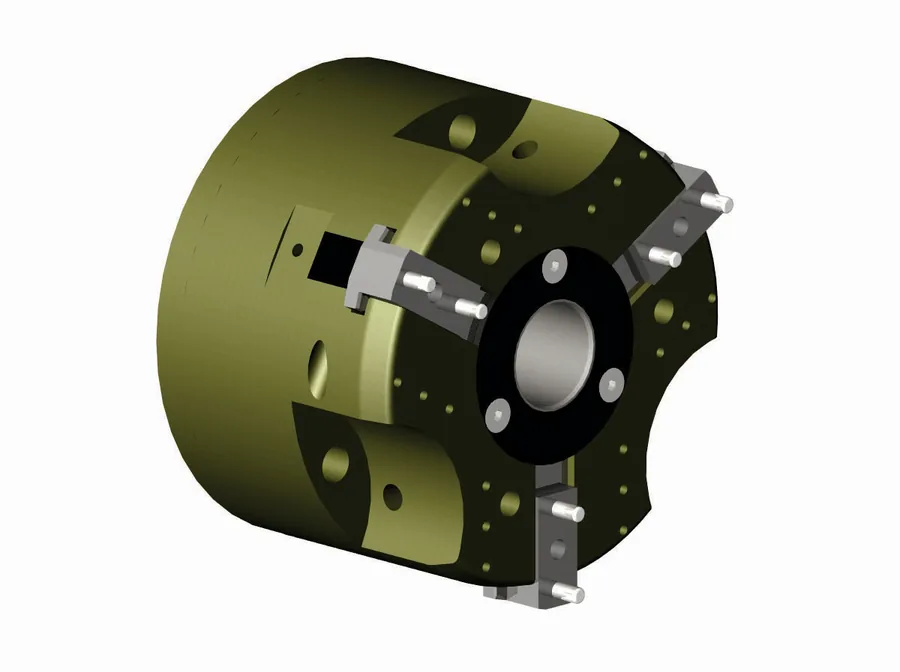
Machine tending
Loading lathes and mills. Three-jaw grippers center round stock and turned parts.
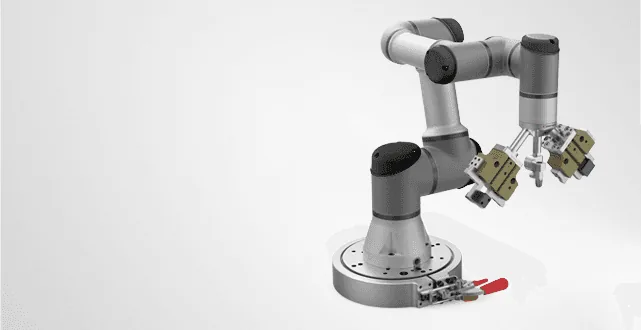
Cobot cells
Lightweight grippers and manual tool changers sized for collaborative robot payloads.
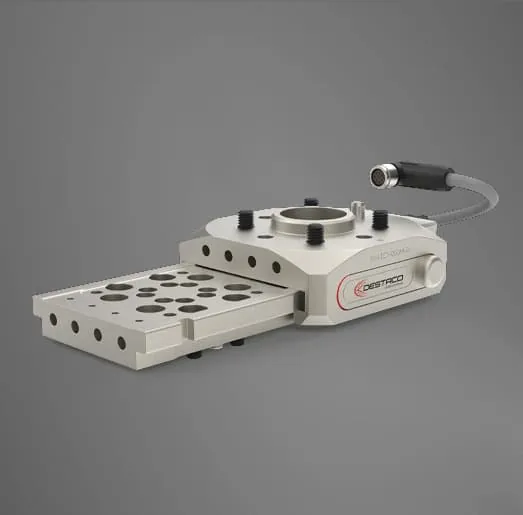
Mixed-product cells
A tool changer lets one robot switch grippers between parts or processes.
When to design in a tool changer
One robot, several jobs
The cell's robot serves processes that each need different tooling.
Mixed product
Each part needs its own gripper and changeovers are frequent.
Heavy tooling
End effectors are too heavy or complex to change by hand.
A tool changer is often cheaper than specifying a second robot into the cell.
The whole pick chain
A station typically needs the part presented (Moorfeed), indexed (Camco), moved (Macron) and gripped (Robohand). EAC can size the chain together.